DC Motor
High-torque DC motor with H-bridge driver for deliberate movements
High-torque DC motor module with integrated H-bridge driver. Supports forward, reverse, and precise speed control. Compact design that extends beyond its port.
For ages 14 and up. Not a toy. Contains small parts: choking hazard. Keep away from children under 3. Adult supervision recommended.
Made by Atech ApS, Lille Strandstræde 6A, st. th., 1254 København K, Denmark.
Technical specifications
- Part
- DC Motor (H-Bridge)
- Interface
- Digital
- Ports
- 1 port
- Current
- ~500 mA
- Size
- 19.5 x 48.3 x 19.1 mm
- Chip
- DRV8833 (Texas Instruments)
Pins
- 3.3V
- supply
- GND
- ground
- Data A
- IN1
- Data B
- IN2
Key features
- High torque for deliberate movements
- Forward and reverse control
- Precise speed control
- Integrated H-bridge driver
Common applications
Technical
DC Motor
DC Motor (H-Bridge)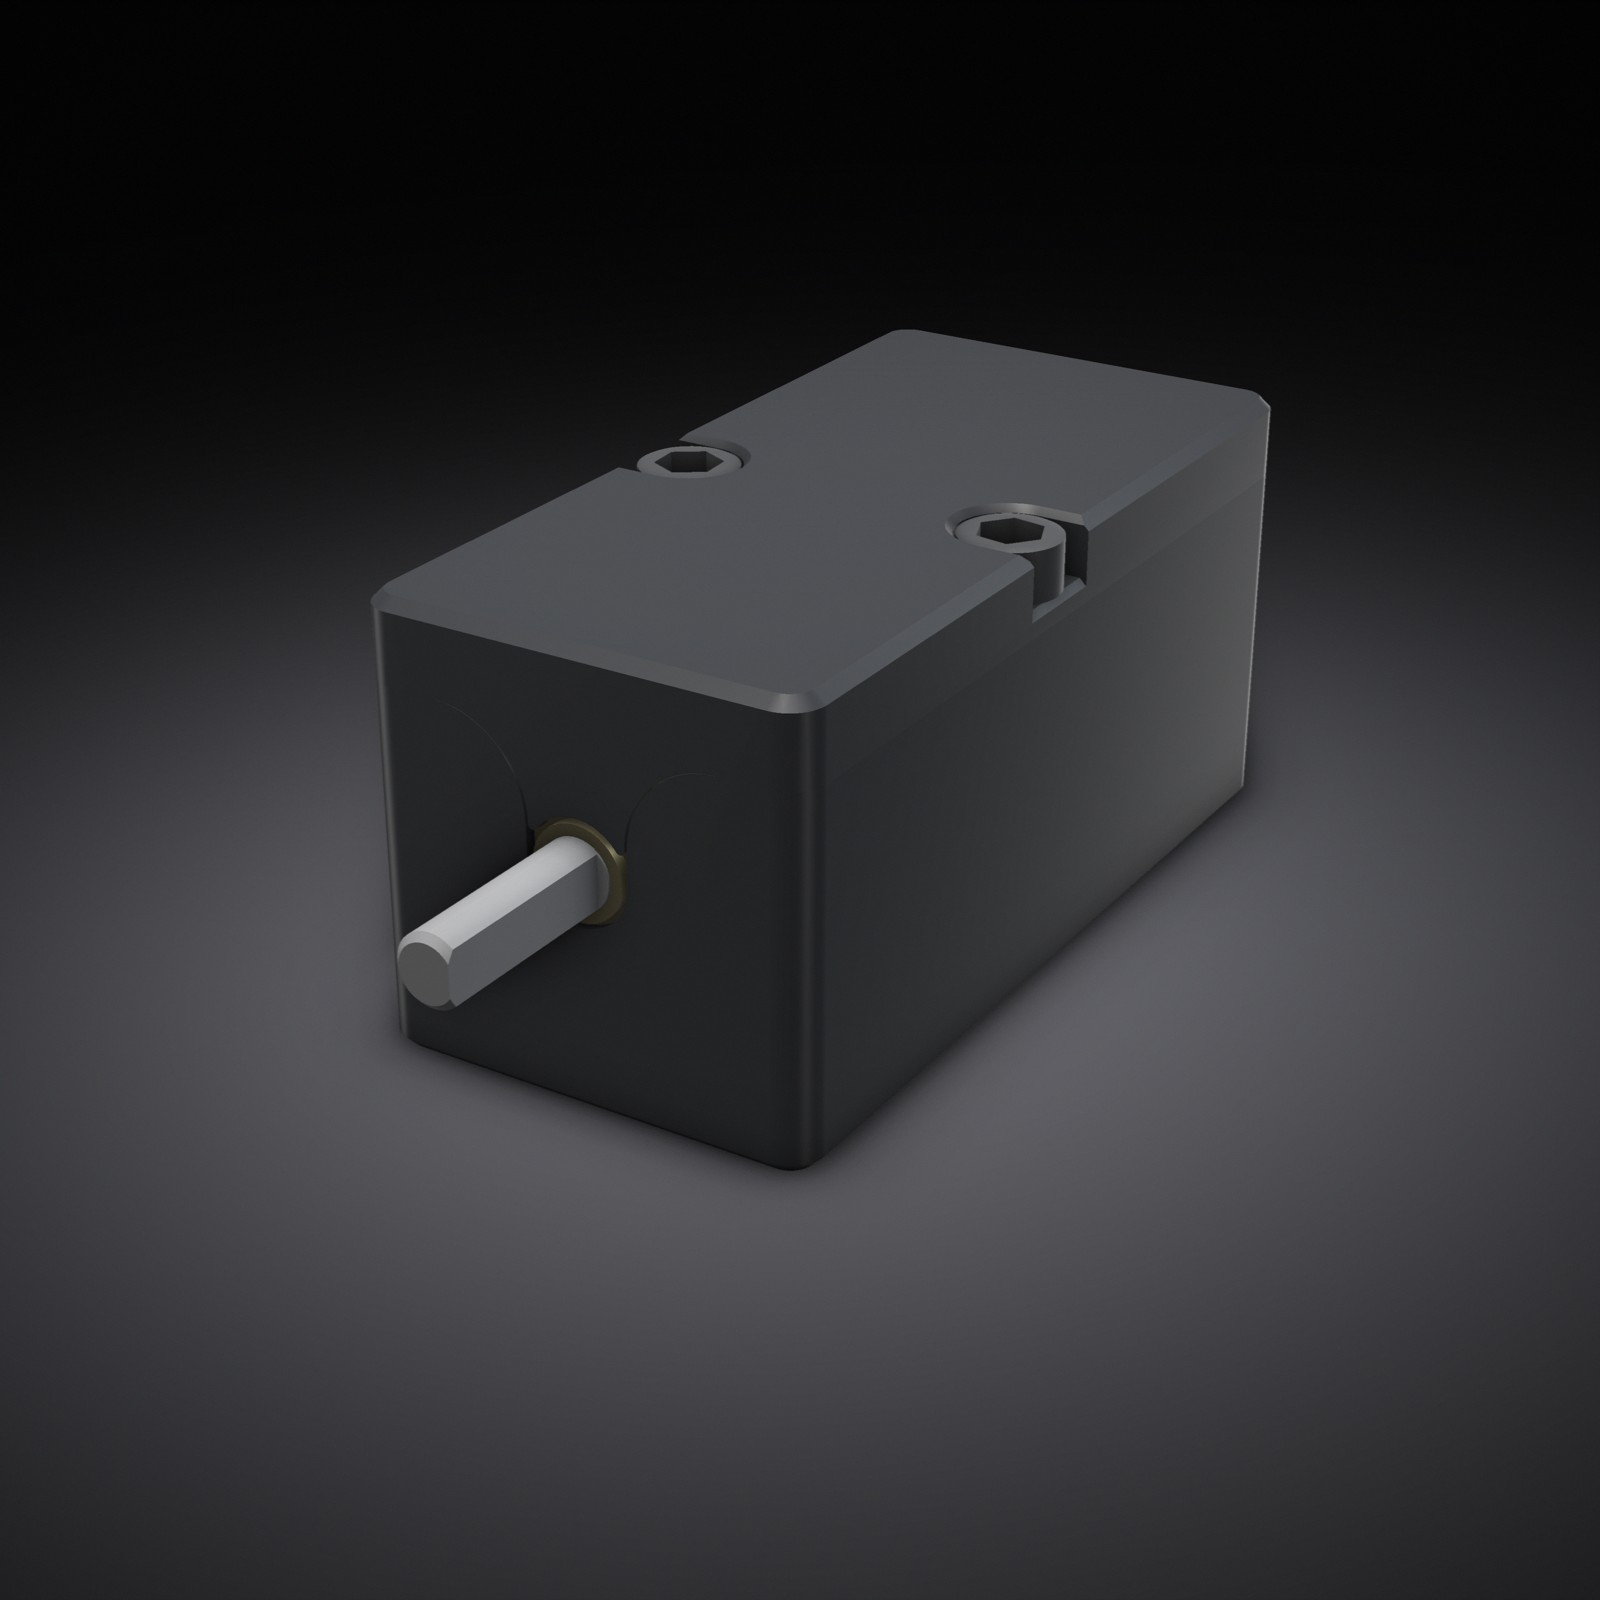
DC motor with H-bridge driver. IN1 on Line B, IN2 on Line A, as the driver is wired (the module's documentation labels them the other way round). Supports PWM speed control.
forwardRun motor forward at specified speed (0-255)reverseRun motor in reverse at specified speed (0-255)stopStop the motor (coast)brakeBrake the motor (active stop)set_speedSet motor speed and direction (-255 to +255)
DC MOTOR (H-Bridge):
- forward(speed) and reverse(speed) take 0–255. stop() coasts, brake() active-stops.
- setSpeed(-255 to +255) combines direction and speed in one call.
- When motors are on OPPOSITE SIDES of a vehicle, they face opposite directions physically.
  To go straight: left motors forward(), right motors reverse() (or vice versa).
- NEVER use analogWrite() or digitalWrite() directly. Always use the motor instance methods.
A horizontal slider from -100 to +100 representing motor speed (negative = reverse) that dispatches a speed action live as it moves. Add a prominent Stop button at center-zero, and a text readout showing current direction + magnitude.
| Pin | Line | Dir | Function |
|---|---|---|---|
| 1 | HV | – | not connected |
| 2 | 5V | – | not connected |
| 3 | 3.3V | input | supply |
| 4 | GND | – | ground |
| 5 | Data A | output | IN1 |
| 6 | Data B | output | IN2 |
from p2p/ground_truth/hardware/prototyping_line/modules/dc_motor.md